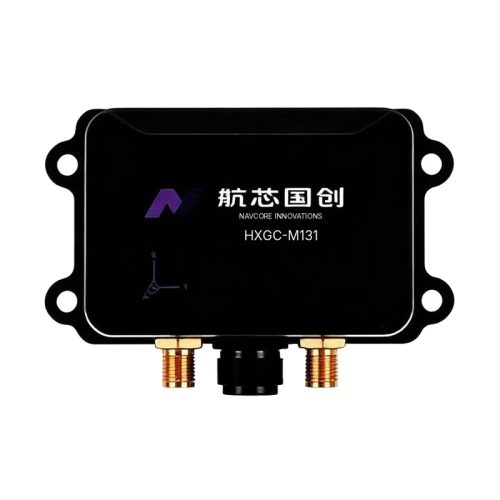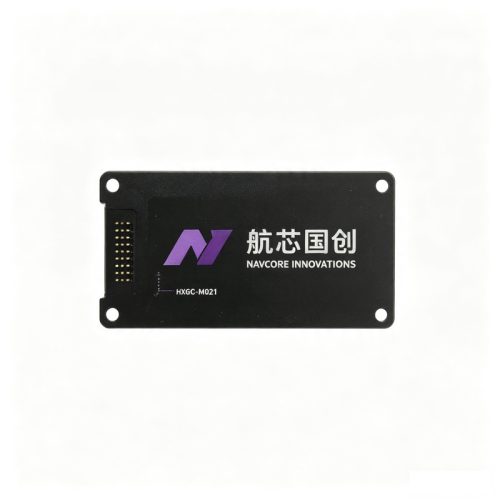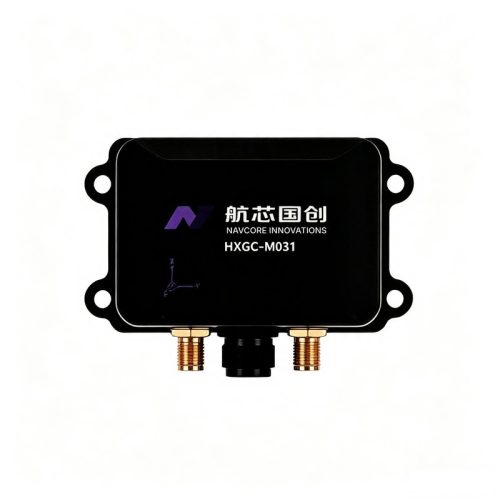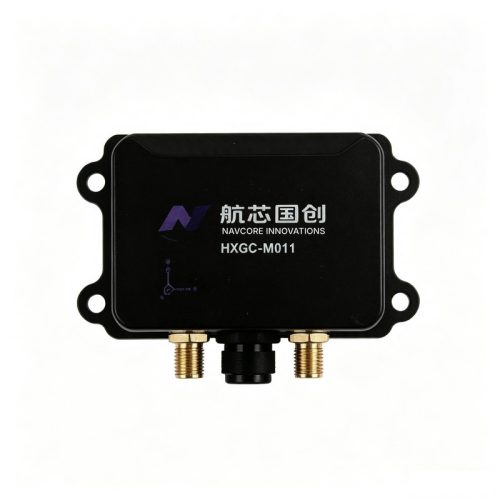
HXGC-M111 is a MEMS Inertial Navigation System (MEMS-INS) independently developed by NavCore, designed as a cost-effective alternative to imported high-end IMUs and for industrial robotics, AGV/AMR, and low-altitude platform integration. It provides inertial measurement, attitude/navigation solution, and interface adaptation capabilities, and is available in two form factors: a compact metal INS housing and a modular board-level card.
The product integrates three-axis angular rate and three-axis linear acceleration acquisition with inertial navigation solution functions. It includes built-in system-level calibration, temperature compensation, and installation error compensation algorithms, with synchronized output of equipment operating status. Interfaces, temperature range, structure, and external configuration are customizable according to customer technical agreements.
Key Specifications
| Parameter | Specification |
|---|---|
| Gyroscope Bias Instability | ≤3°/h |
| Angular Random Walk (ARW) | ≤0.03°/√h |
| Range / Accuracy | MEMS-INS; navigation/attitude accuracy confirmed by model datasheet / technical agreement |
| Output / Interface | UART / RS422 / CAN / SPI, configurable per customer agreement |
| Dimensions / Weight | Size, weight, power supply, and temperature range confirmed by model datasheet / technical agreement |
Product Features
-
Compact metal INS housing / modular board-level card, dual form factor
-
System-level calibration
-
Temperature compensation
-
Installation error compensation
-
Interfaces, temperature range, structure, and external configuration customizable per customer agreement
-
Fast deployment as a cost-effective alternative to imported high-end IMUs
Applications
-
AGV/AMR mobile platforms — validation of the MEMS-INS solution independently developed by NavCore, indoor/outdoor switching, and short-term trajectory hold
-
Industrial robots and mobile robots — attitude feedback and trajectory assistance
-
Embodied intelligence and low-altitude platforms — integration of inertial units independently developed by NavCore